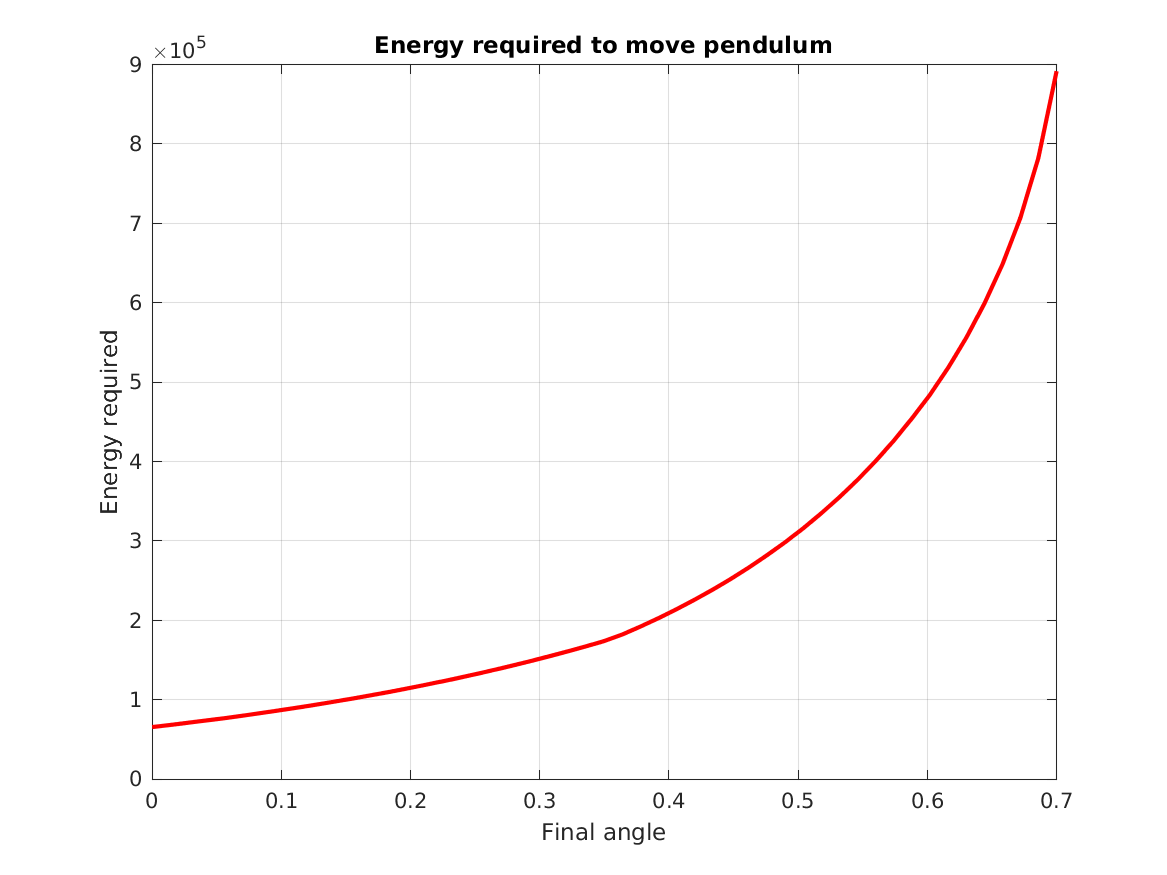
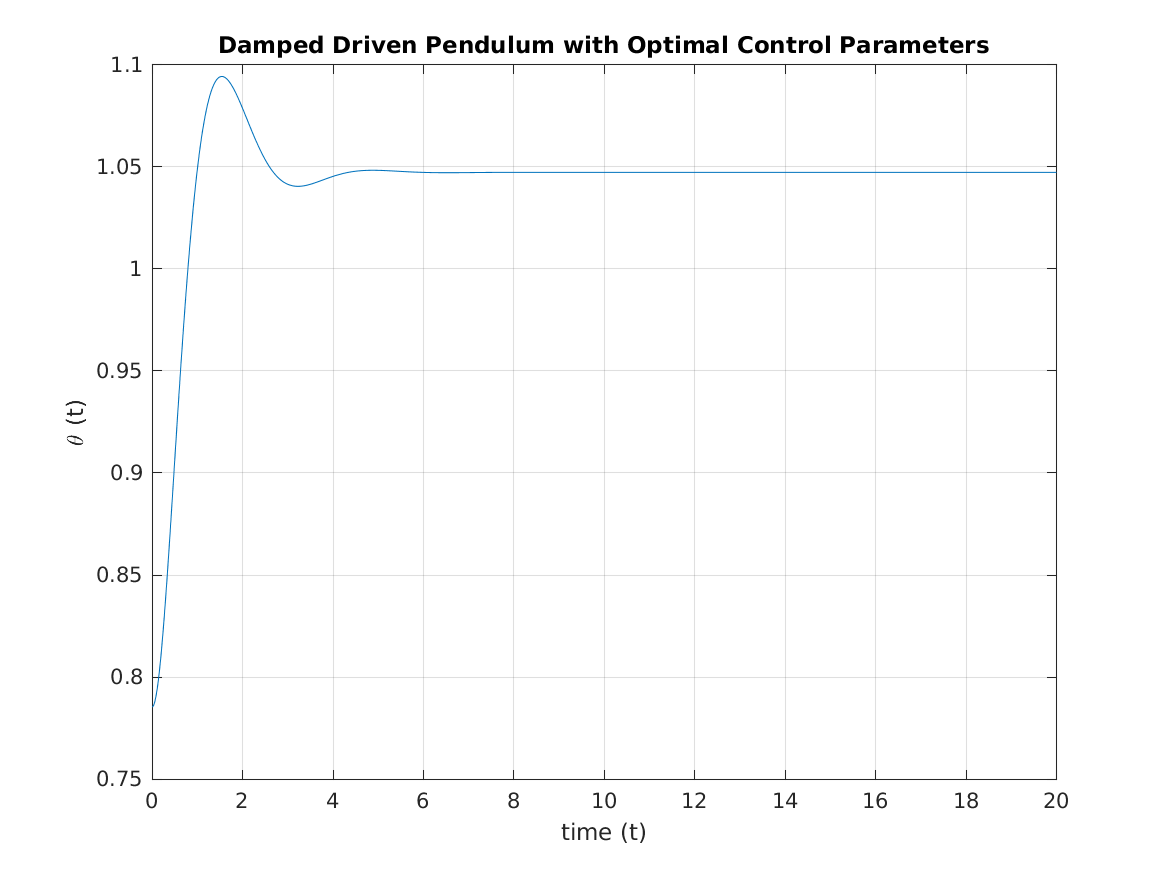
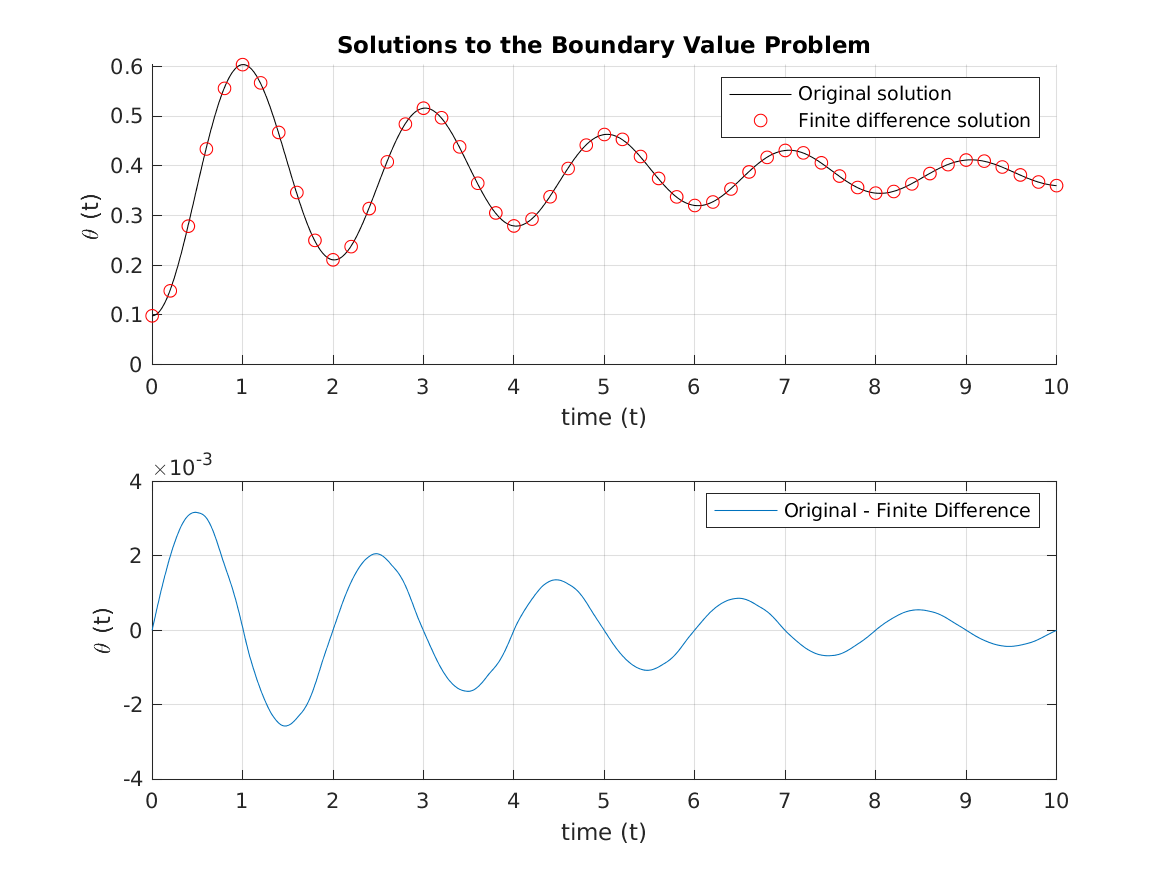
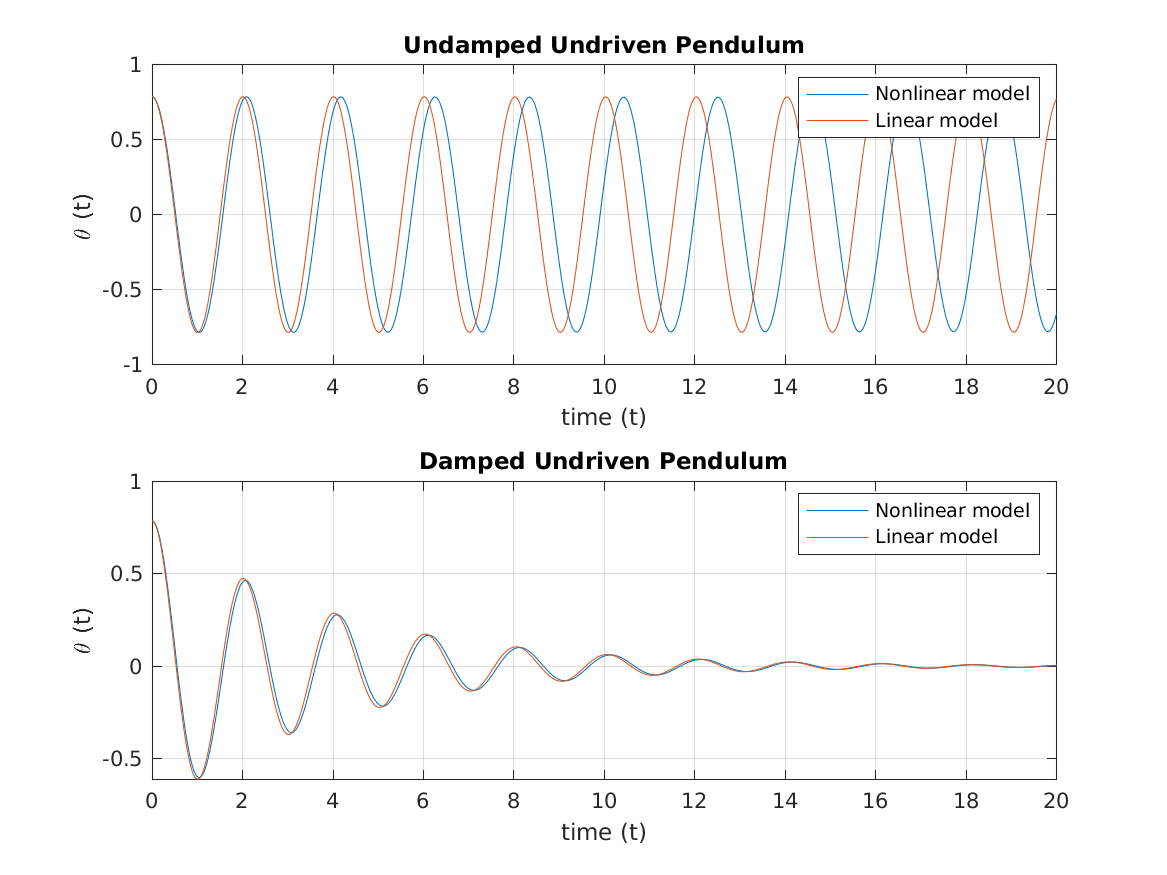
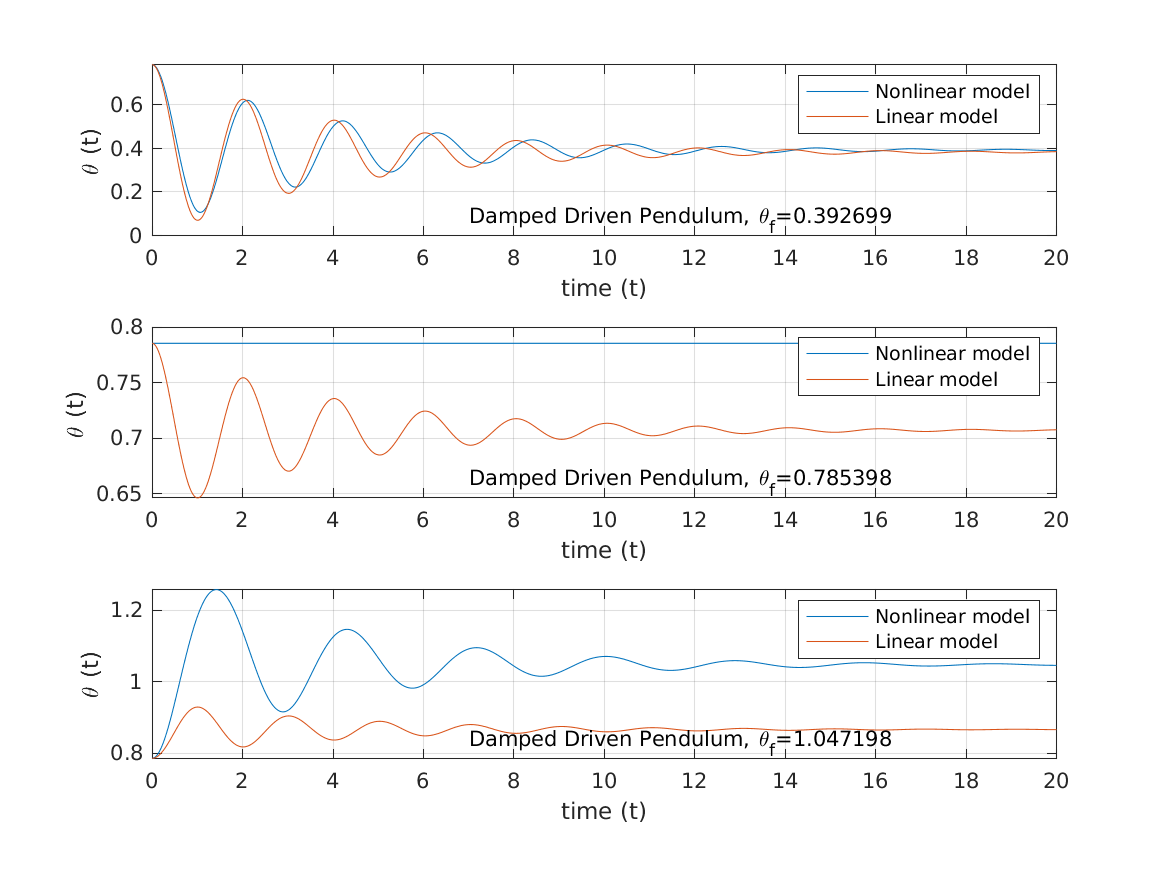
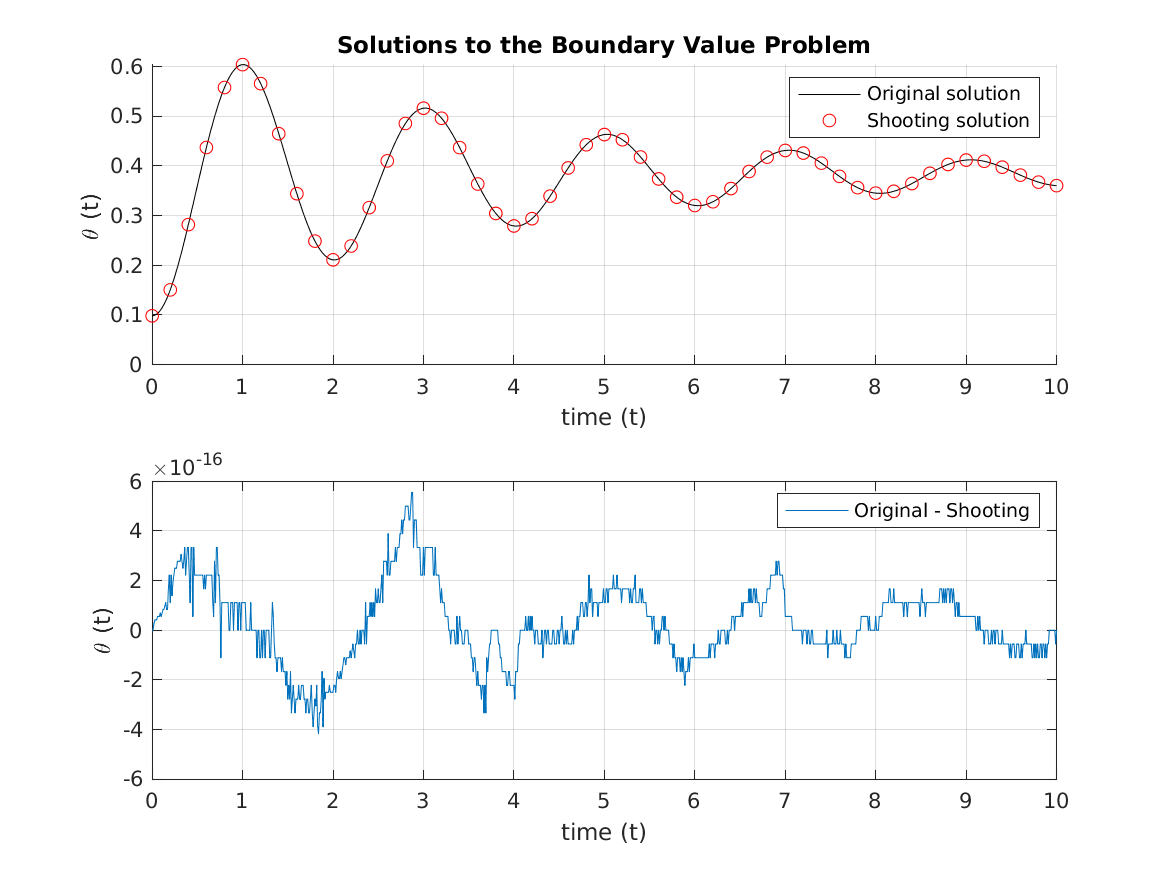
pendulum_control_ode_test, a MATLAB code which calls pendulum_control_ode(), which studies the stability, behavior, and control of a robot arm that is modeled as a damped, driven pendulum. It is based on a case study by Dianne O'Leary, "Swinging Like a Pendulum".
The information on this web page is distributed under the MIT license.
pendulum_control_ode, a MATLAB code which studies the stability, behavior, and control of a robot arm that is modeled as a damped, driven pendulum. It is based on a case study by Dianne O'Leary, "Swinging Like a Pendulum".